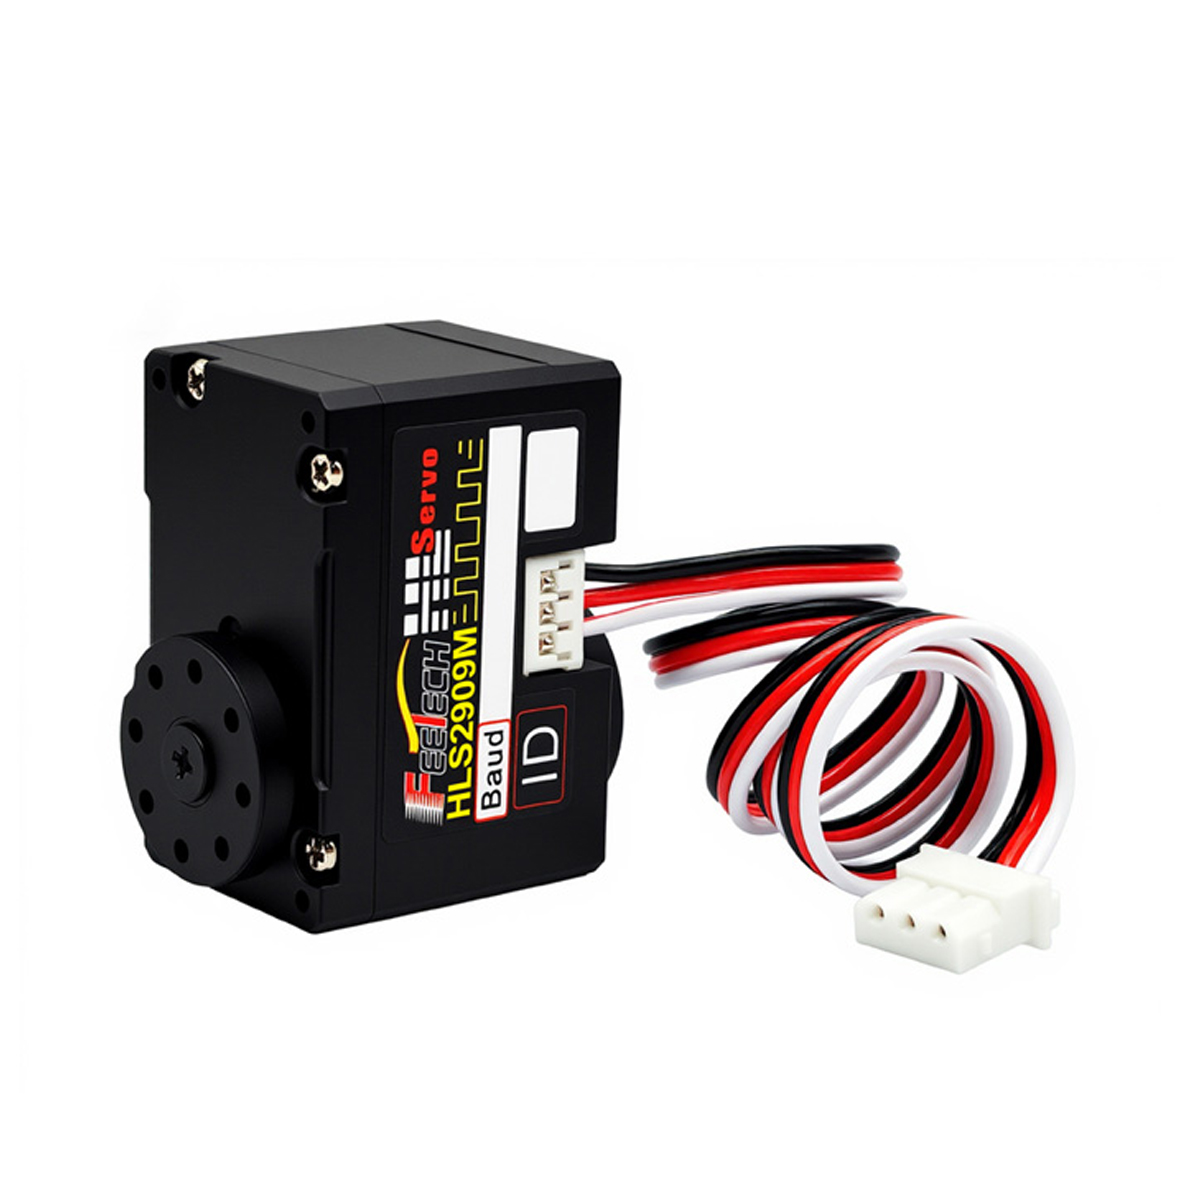
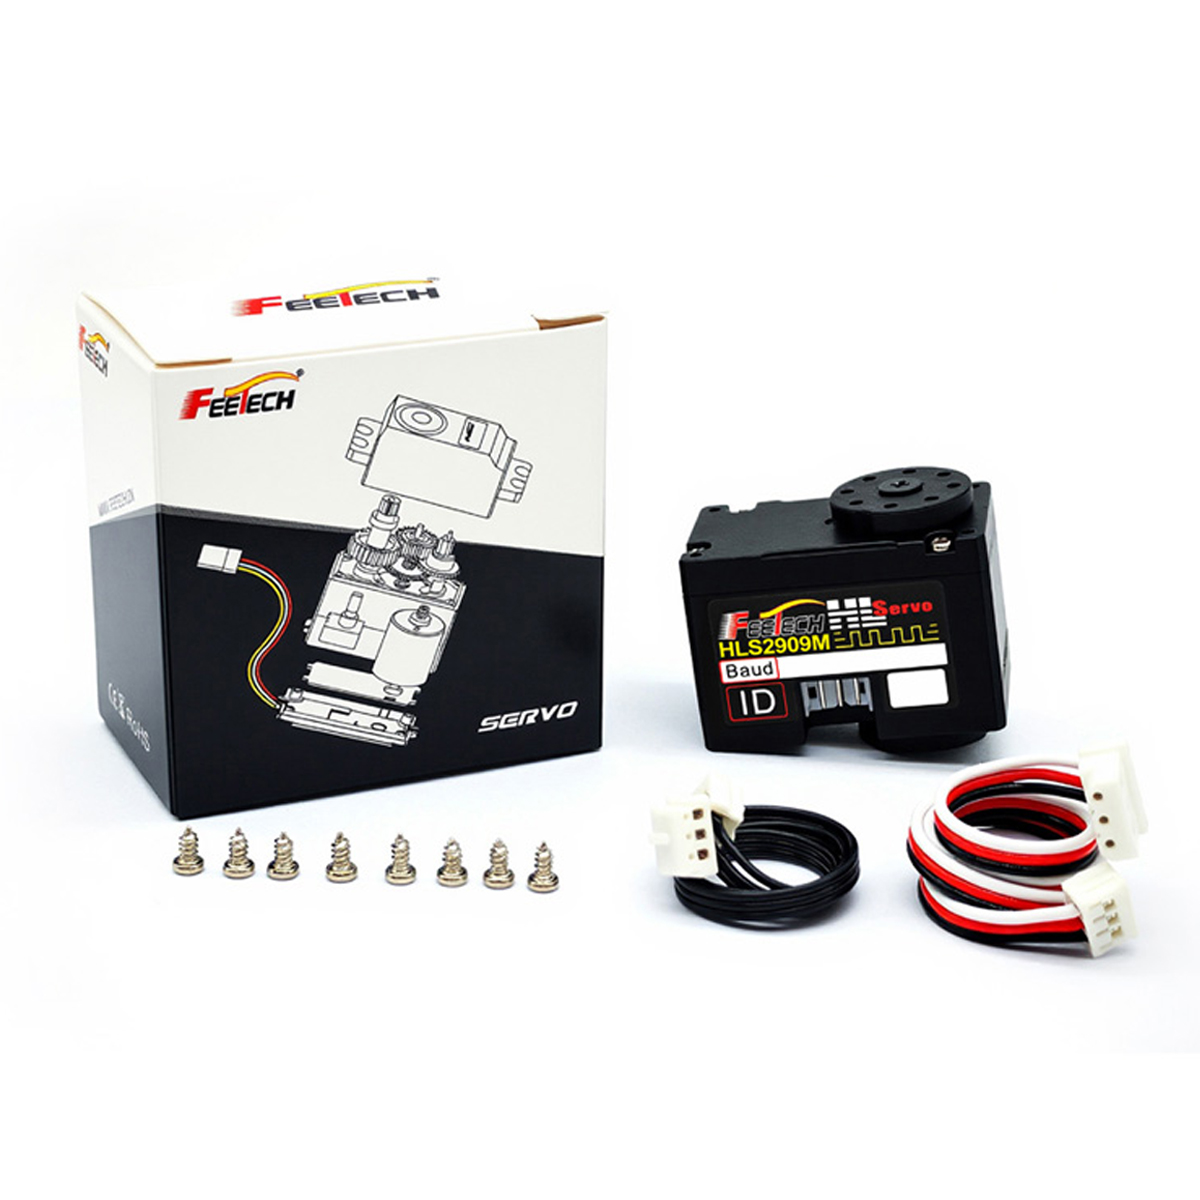
Model: HL-2909-C001
Storage Temperature Range: -30℃~80℃
Operating Temperature Range: -10℃~60℃
Temperature Range: 25℃ ±5℃
Humidity Range: 65%±10%
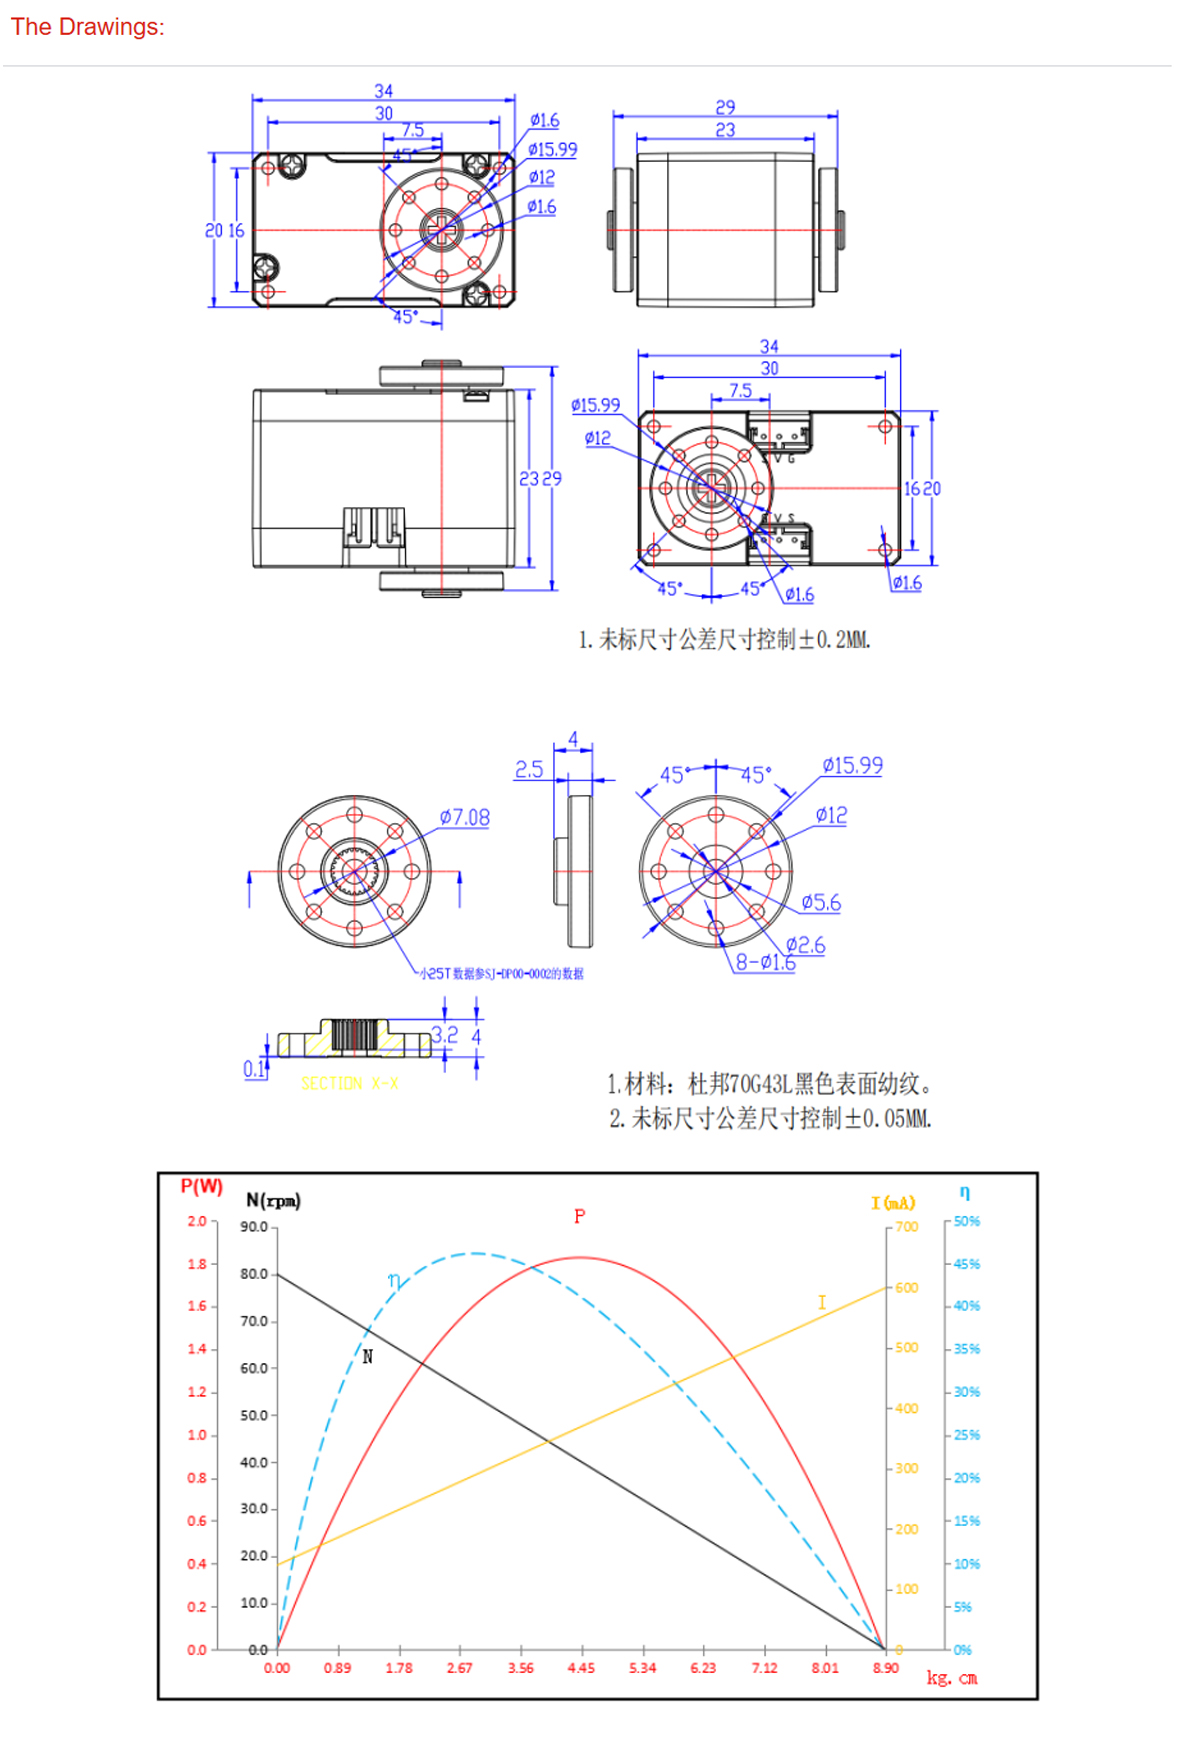
Size: 34*20*23mm
Weight: 22.5±2g
Gear Type: Metal Gear
Limit Angle: No Limit
Bearing: Ball Bearings
Horn Gear Spline: 25T/OD4.95mm
Gear Ratio: 1/320
Back Lash: ≦1°
Case: PA+Fiber
Connector Wire: 15CM/20CM
Motor: Core Motor
Rated Input Voltage: 9V-14V
No-Load Speed: 0.13sec/60°(77RPM)@12V
Running Current(At No-Load): 140mA@12V
Peak Stall Torque: 8.9kg.cm@12V
Stall Current: 0.6A@12V
Rated Load: 2.9kg.cm@12V
Rated Current: 200mA@12V
KT Constant: 14.83kg.cm/A
Operating Modes: Mode 0: Angle servo mode (default mode, absolute position controllable from 0-360 degrees); Mode 1: Motor constant speed mode (maintains speed without deceleration as the load increases); Mode 2: Motor constant current mode (maintains current without decreasing with increasing load)
Multi-Loop Mode: Control of positive and negative 7 turns at the highest accuracy, but the number of turns will not be saved after power off (resolution can be expanded, number of turns can be doubled)
Constant Force Output: Set the output torque value, the servo can maintain this torque (input the target torque value corresponding to address 44, the servo can maintain this torque)
Command Signal: Digital Packet
Protocol Type: Half Duplex Asynchronous Serial Communication
ID Range: 0-253
Communication Speed: 38400bps ~ 1Mbps
Control Algorithm: PID
Neutral Position: 2048
Running Degree: 360° (when 0~4095)
Resolution: 0.088°(360°/4096)
Rotating Direction: Clockwise(0→4095)
Feedback: Load, Position, Speed, Input Voltage, Current, Temperature